Abstract
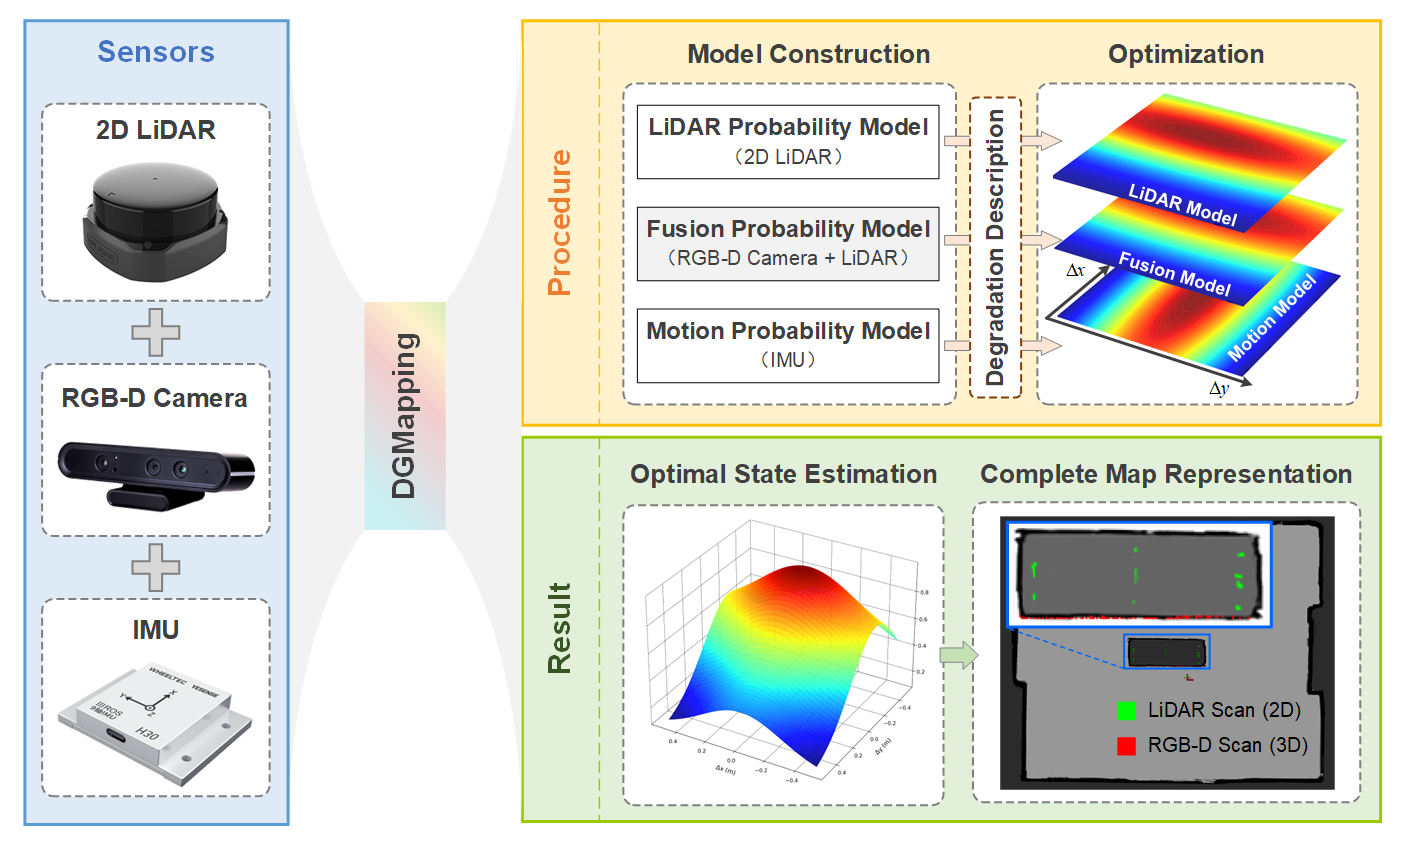
2D LiDAR is widely employed for map construction due to its cost-effectiveness and reliable measurements. However, its inherent limitation of single-plane scanning constrains the dimensionality and scale of the observed data, resulting in degeneration caused by insufficient geometric constraints. Although LiDAR-inertial fusion enhances mapping by compensating for LiDAR degeneration through motion correction, it struggles with accumulating sensor errors and fails to capture comprehensive 3D structural information.
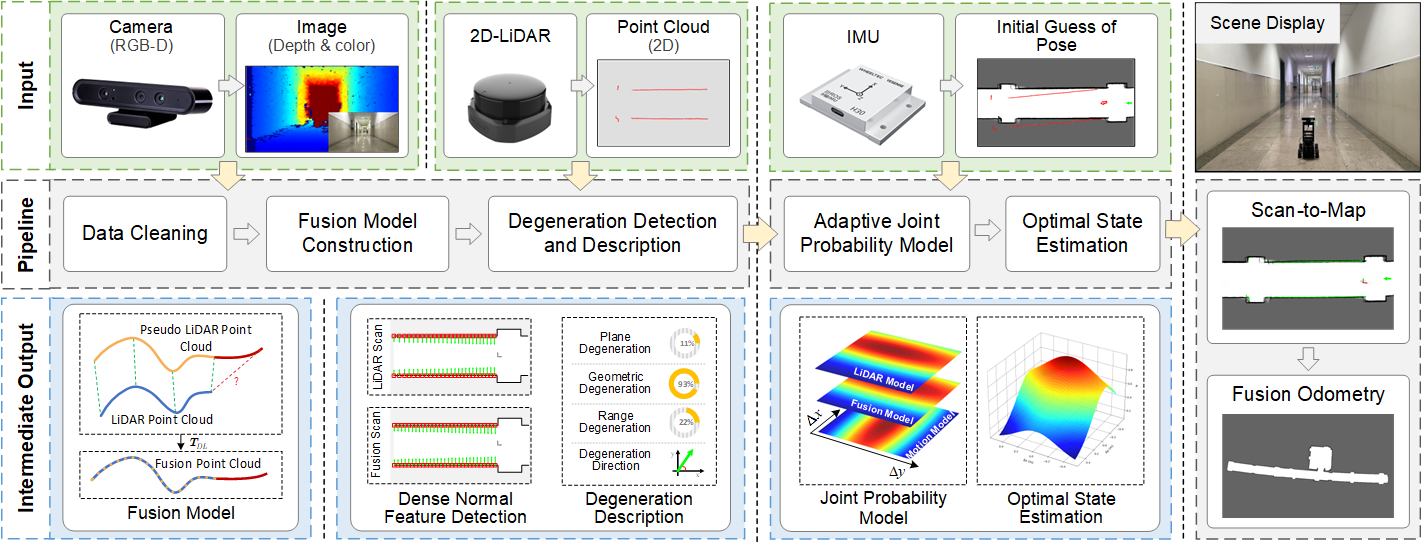
In this paper, we focus on enhancing environmental data utilization, refining the observation model, and integrating 3D structural information to improve mapping quality, rather than relying solely on low-precision motion compensation. We introduce DGMapping, a cost-effective multi-sensor fusion framework that follows a standardized process from joint probabilistic model construction to optimization. During the model construction phase, we incorporate a sampling-optimized fusion observation model to improve the efficiency and completeness of environmental data utilization. Additionally, we further refine the scene degeneration description to enhance the adaptive optimization of the joint probabilistic model. Experimental results across six real-world scenarios demonstrate that DGMapping outperforms existing algorithms in terms of odometry and mapping performance.
Framework
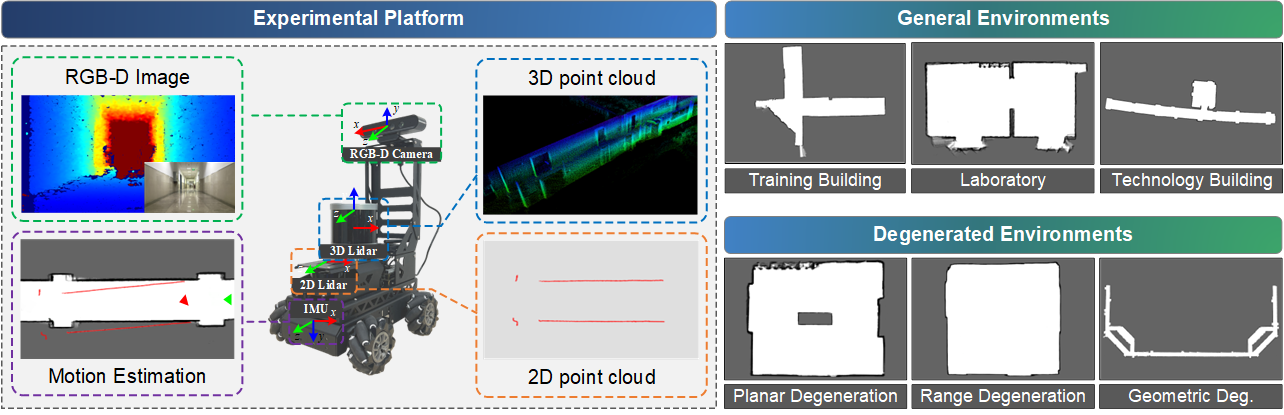
Experimental Setup
Quantitative Results
| Method | Geometric Degeneration | Range Degeneration | Planar Degeneration | Average CE ↓ | ||||||||||
|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|
| ATE [m] ↓ | ARE [rad] ↓ | ATE [m] ↓ | ARE [rad] ↓ | ATE [m] ↓ | ARE [rad] ↓ | |||||||||
| RMSE | STD | RMSE | STD | RMSE | STD | RMSE | STD | RMSE | STD | RMSE | STD | |||
| ORB-SLAM3 | 2.731 | 0.946 | 0.021 | 0.013 | 1.502 | 0.671 | 0.025 | 0.011 | 0.046 | 0.009 | 0.007 | 0.003 | 0.722 | |
| Hector | 13.535 | 5.292 | 0.027 | 0.013 | 12.357 | 6.469 | 0.117 | 0.063 | 5.582 | 2.136 | 0.021 | 0.012 | 6.328 | |
| Karto | 11.283 | 5.195 | 0.026 | 0.012 | 10.957 | 5.264 | 0.192 | 0.119 | 3.435 | 1.719 | 0.019 | 0.010 | 4.319 | |
| CSM | θ = 1.0 | 10.325 | 4.879 | 0.029 | 0.014 | 9.773 | 5.132 | 0.073 | 0.044 | 3.253 | 1.658 | 0.017 | 0.009 | 3.912 |
| θ = 0.5 | 8.858 | 3.694 | 0.037 | 0.025 | 6.633 | 3.197 | 0.168 | 0.095 | 1.146 | 0.732 | 0.028 | 0.019 | 2.812 | |
| θ = 0.1 | 5.222 | 1.941 | 0.084 | 0.052 | 5.504 | 2.677 | 0.191 | 0.119 | 0.946 | 0.632 | 0.036 | 0.026 | 1.997 | |
| Cartographer | 4.231 | 1.289 | 0.027 | 0.014 | 3.643 | 1.912 | 0.085 | 0.036 | 0.930 | 0.293 | 0.029 | 0.017 | 1.490 | |
| DN-CSM | 3.038 | 1.136 | 0.015 | 0.008 | 3.044 | 1.573 | 0.035 | 0.017 | 0.913 | 0.597 | 0.032 | 0.021 | 1.180 | |
| DGMapping (w/o) | 2.135 | 0.994 | 0.013 | 0.007 | 2.802 | 1.307 | 0.033 | 0.016 | 0.441 | 0.206 | 0.025 | 0.014 | 0.908 | |
| DGMapping (ours) | 1.997 | 0.841 | 0.013 | 0.007 | 2.541 | 1.151 | 0.032 | 0.015 | 0.184 | 0.080 | 0.011 | 0.006 | 0.796 | |
| Method | Science Building | Laboratory | Training Center | Average CE ↓ | ||||||||||
|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|
| ATE [m] ↓ | ARE [rad] ↓ | ATE [m] ↓ | ARE [rad] ↓ | ATE [m] ↓ | ARE [rad] ↓ | |||||||||
| RMSE | STD | RMSE | STD | RMSE | STD | RMSE | STD | RMSE | STD | RMSE | STD | |||
| ORB-SLAM3 | 0.320 | 0.119 | 0.020 | 0.009 | 2.392 | 0.814 | 0.073 | 0.046 | 0.446 | 0.043 | 0.025 | 0.015 | 0.546 | |
| Hector | 5.242 | 2.207 | 0.021 | 0.013 | 13.665 | 6.078 | 0.069 | 0.046 | 1.173 | 0.597 | 0.023 | 0.016 | 3.366 | |
| Karto | 4.152 | 1.623 | 0.025 | 0.014 | 5.783 | 3.019 | 0.129 | 0.084 | 1.132 | 0.511 | 0.021 | 0.011 | 1.873 | |
| CSM | θ = 1.0 | 4.543 | 1.838 | 0.022 | 0.013 | 7.731 | 3.635 | 0.085 | 0.067 | 0.224 | 0.104 | 0.021 | 0.011 | 2.104 |
| θ = 0.5 | 3.486 | 1.502 | 0.026 | 0.015 | 6.244 | 3.156 | 0.093 | 0.075 | 0.961 | 0.439 | 0.027 | 0.018 | 1.806 | |
| θ = 0.1 | 3.015 | 1.094 | 0.037 | 0.021 | 5.551 | 2.957 | 0.137 | 0.098 | 1.266 | 0.611 | 0.034 | 0.021 | 1.673 | |
| Cartographer | 1.845 | 0.719 | 0.022 | 0.011 | 2.619 | 0.948 | 0.099 | 0.051 | 0.211 | 0.099 | 0.020 | 0.011 | 0.802 | |
| DN-CSM | 0.446 | 0.141 | 0.021 | 0.012 | 2.508 | 0.884 | 0.069 | 0.044 | 0.206 | 0.105 | 0.019 | 0.012 | 0.545 | |
| DGMapping (w/o) | 0.327 | 0.146 | 0.020 | 0.011 | 1.936 | 0.891 | 0.068 | 0.044 | 0.199 | 0.097 | 0.020 | 0.013 | 0.428 | |
| DGMapping (ours) | 0.307 | 0.148 | 0.019 | 0.011 | 1.617 | 0.721 | 0.067 | 0.043 | 0.173 | 0.069 | 0.016 | 0.010 | 0.367 | |
Absolute Trajectory Error (ATE, m) and Absolute Rotational Error (ARE, rad) are reported. Proposed method Visual reference (degenerate table). Bold and underlined values indicate the best and second-best results.
Mapping Results
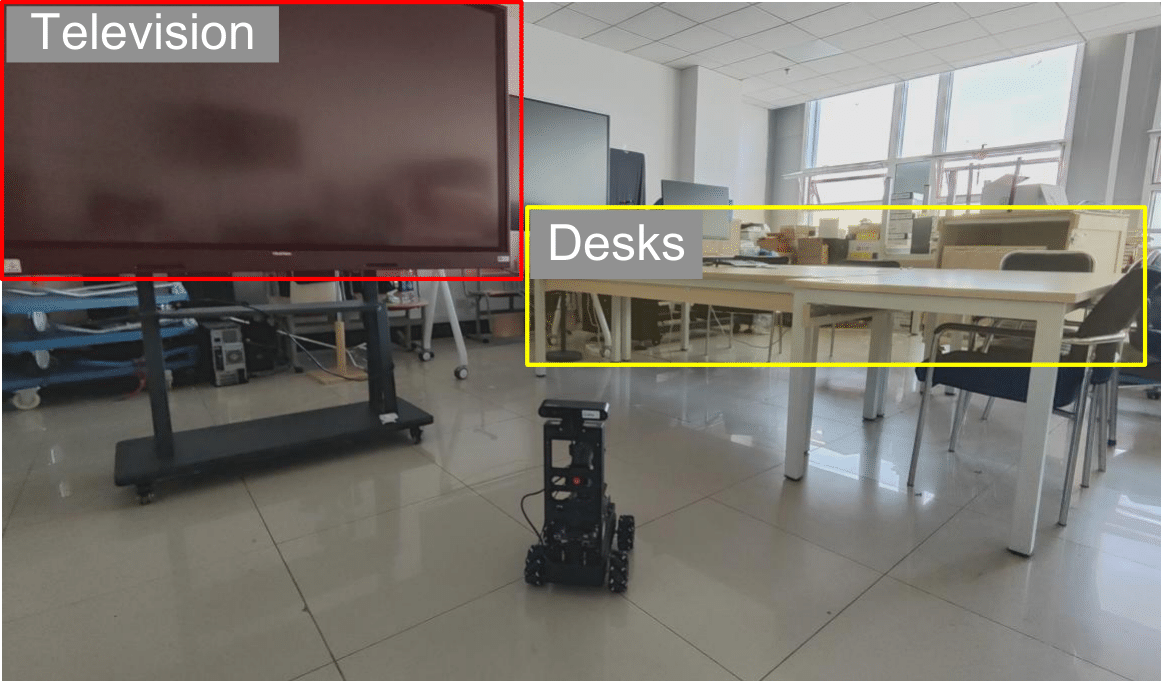
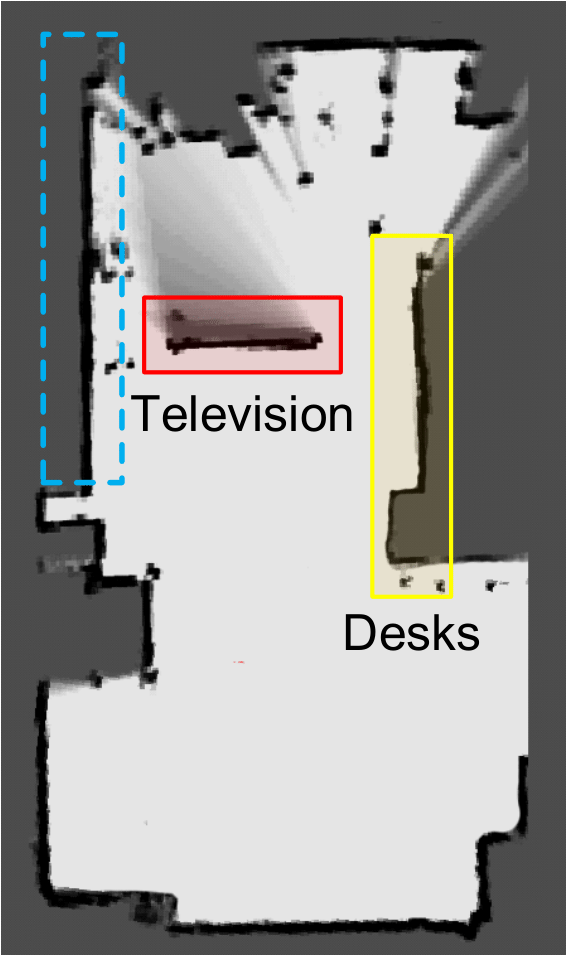
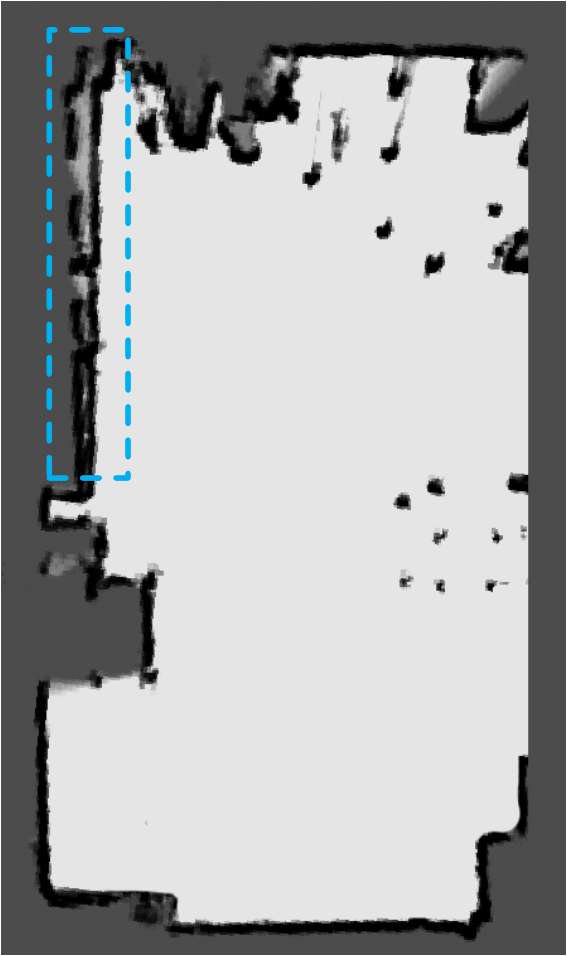
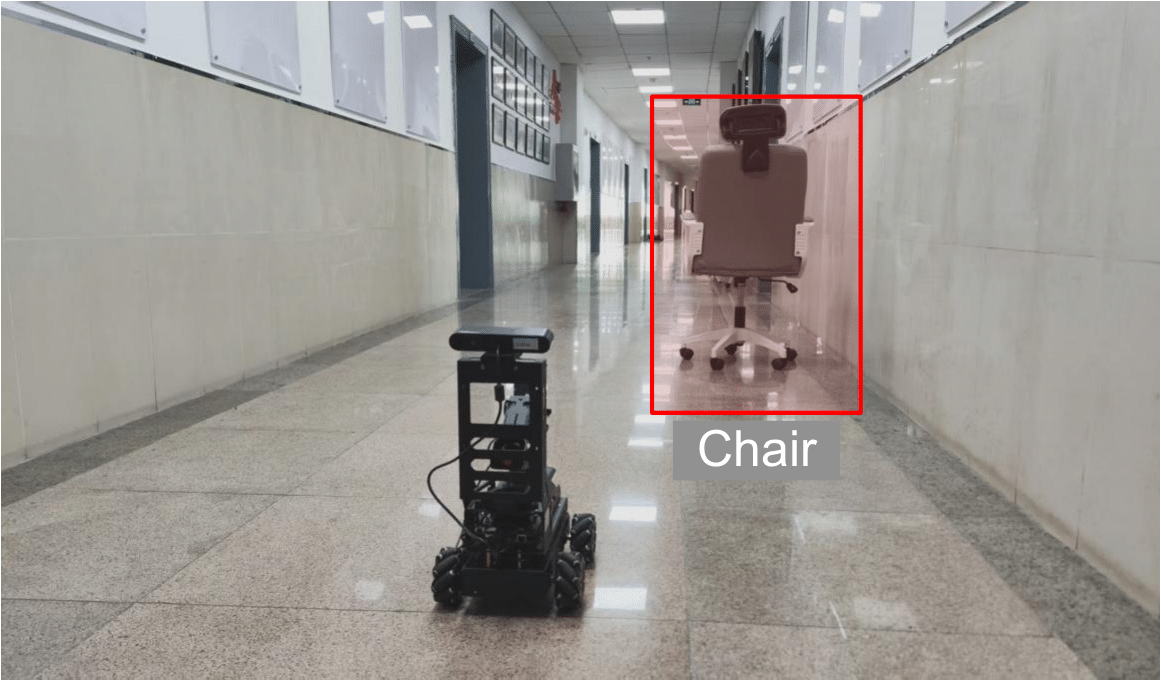
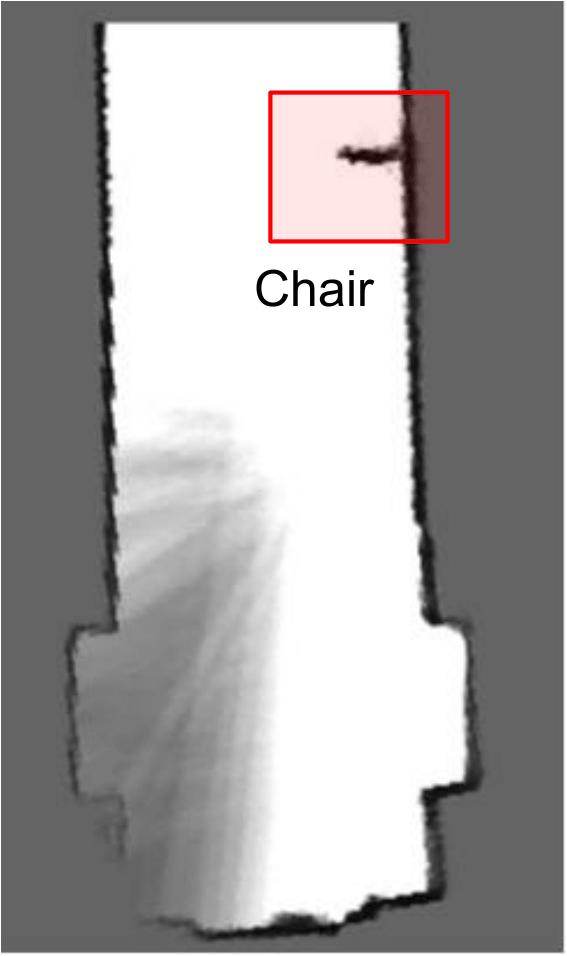
Mapping results for Tech Tower and corridor scenes. The top row displays the scene overviews, while the bottom row compares the mapping outcomes of DGMapping and DN-CSM. Images are cropped for clarity.
Efficiency & Cost Analysis
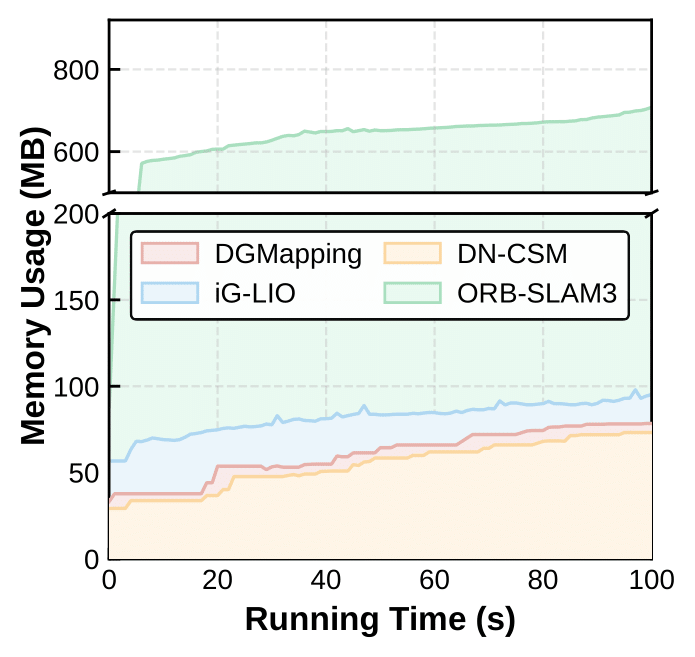
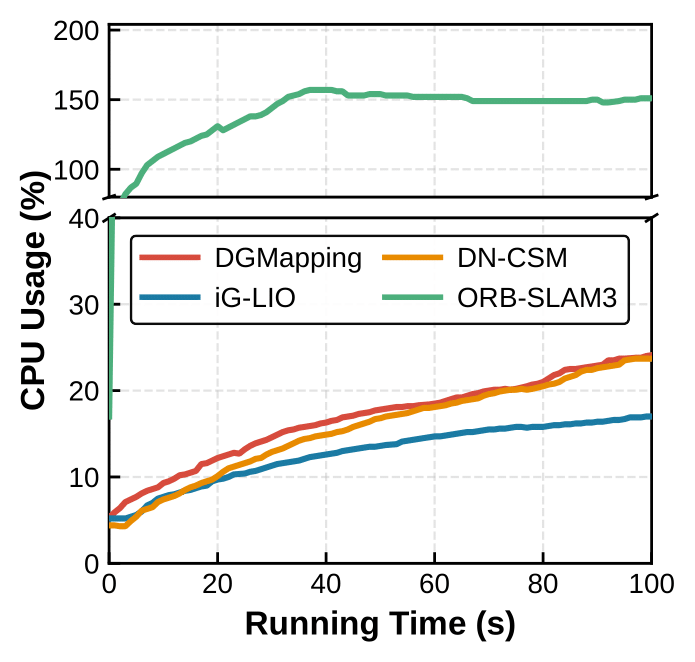
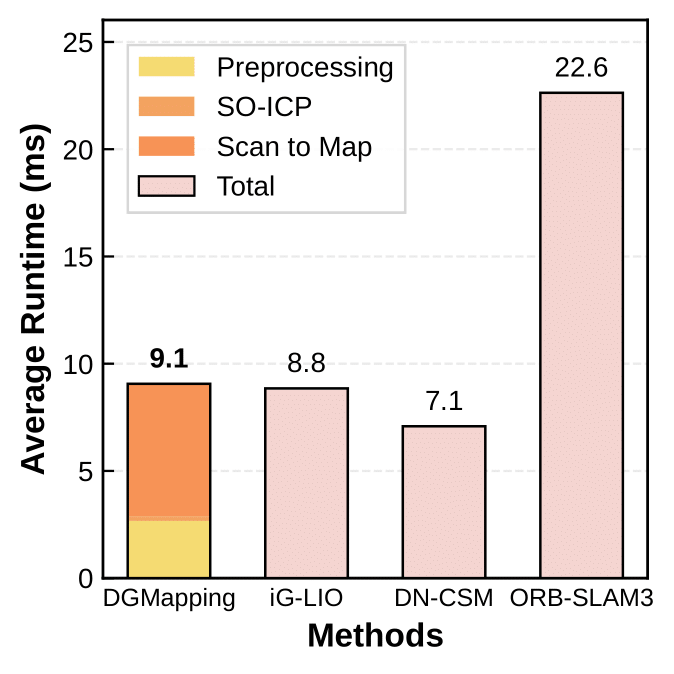
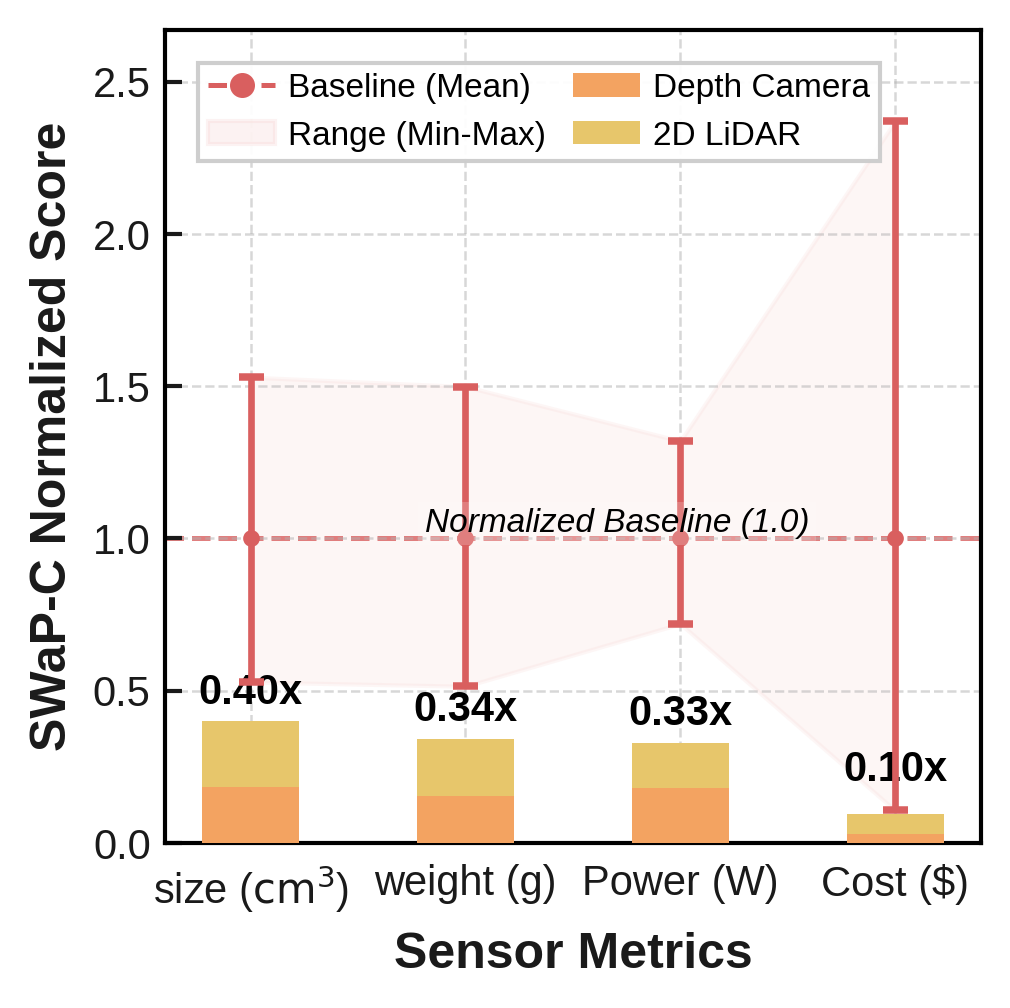
Computational efficiency and resource evaluation. (a) Memory footprint monitoring shows the memory consumption patterns of different algorithms. (b) CPU usage statistics demonstrate the computational load distribution. (c) Runtime analysis of system components highlights the time efficiency of each module. (d) Comprehensive SWaP-C (Size, Weight, Power, and Cost) metrics comparison against baselines.
Citation
@article{11569794,
  author  = {Liu, Yu and Li, Zhongyu and Zhou, Meiqi and Fan, Zipei and Feng, Guanyuan},
  journal = {IEEE Transactions on Instrumentation and Measurement},
  title   = {DGMapping: Degeneration-Guided Adaptive Multisensor Fusion for Cost-Effective Mapping},
  year    = {2026},
  volume  = {75},
  pages   = {9526218-9526218},
  doi     = {10.1109/TIM.2026.3704099}
}